Street Light Cable Fault Tester
Equipment Introduction
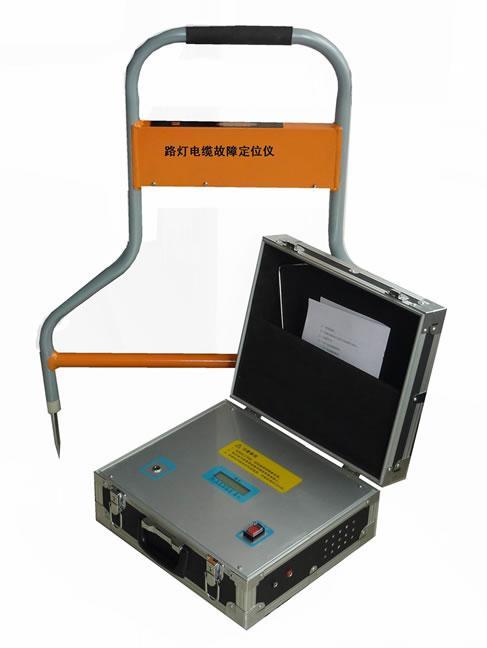
TPLDC The Street Light Cable Fault Tester consists of a transmitter, receiver, magnetic induction probe, and positioning detection frame. This instrument is a specialized device for fault location testing of optical cables and cables, suitable for testing various optical cables and cables with metal conductors (wire pairs, sheaths, shielding layers). The main functions of this Street Light Cable Fault Tester include locating insulation faults to ground, detecting cable paths, and measuring cable burial depth.
Working Principle
1. Tracing Principle (Signal Method)
When an alternating current flows through a conductor, an alternating magnetic field is generated around the conductor, and the magnetic field lines are coaxial with the conductor. If an electromagnetic coil is placed in this magnetic field, an induced voltage will be generated at both ends of the coil. When moving the induction coil, when the direction of the coil is the same as the direction of the magnetic field lines, the induced voltage at both ends of the coil will be maximum. That is, when the coil direction is perpendicular, the induced voltage is maximum; when the coil direction is parallel to the conductor direction, the induced voltage is minimum (as shown in Figure 2). Thus, we obtain the "maximum signal method" to trace the path of buried cables, and the burial depth of underground cables can be measured using the 45° rule of the receiving coil.
2. Positioning Principle
(1) Differential Potential Method
If a buried cable has a ground fault, the potential difference method can be used to find the fault point. The method is to apply a test voltage between the test point of the faulty cable and the ground. Then, a distributed electric field centered at the grounding point will be formed around the cable entry point. There is no potential difference between any two points with the same radius in this electric field, but there is a potential difference between any two points with different radii (such as points A and B in the figure). Moreover, when the distance between the two points is fixed, the closer the two points are to the center, the stronger the potential difference.
Using this characteristic, we can move points A and B gradually closer to the center point. When the fault point is exactly between points A and B, the potential difference becomes zero. If we continue moving past the fault point, the polarity of the potential difference will reverse. By moving back and forth in this way, the grounding point can be accurately determined.
(2) Vibration Detection Method
When the cable exhibits a high-resistance fault and the impulse flashover method must be used to detect the fault, the discharge of the fault point to ground will cause slight vibrations on the ground surface. At this time, a vibration sensor can be used to detect the epicenter to find the fault point.
Equipment Features
1. High receiving sensitivity
2. Low static drift
3. High positioning accuracy
4. Strong anti-interference capability
5. LCD screen displays signal and status
6. Built-in lithium battery power supply, with charger included
Technical Specifications
1. Tracing and positioning distance: 3km for local telephone cables, up to 20km for other cables
2. Positioning impedance range: 0~5MΩ
3. Positioning accuracy: <±10cm
4. Burial depth detection: <3m